Soft Gripper Fruit Pack
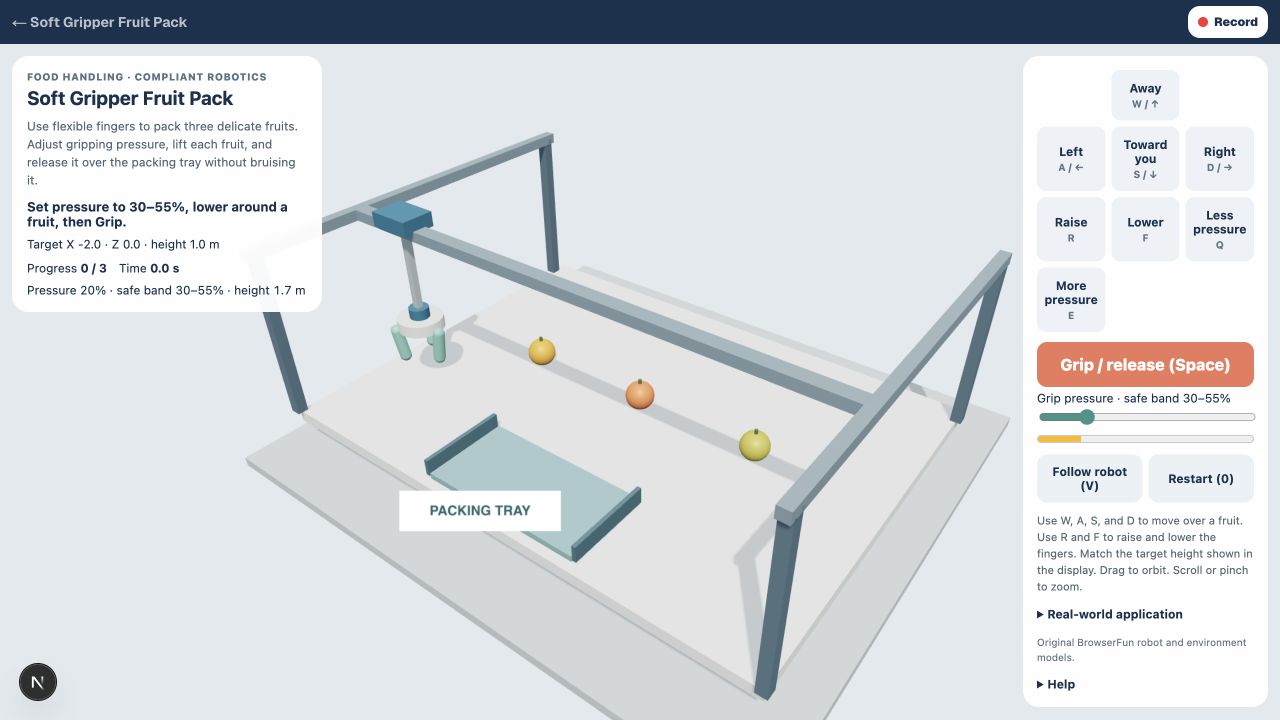
Use flexible fingers to pack three delicate fruits. Adjust gripping pressure, lift each fruit, and release it over the packing tray without bruising it.
How to play Soft Gripper Fruit Pack
- 1
Position the fingers
Use W, A, S, and D to move over a fruit. Use R and F to raise and lower the fingers. Match the target height shown in the display.
- 2
Find a gentle pressure
Use the pressure slider or Q and E. The safe teaching range is 30–55%. Press Grip or Space to hold the fruit. Too little pressure slips; too much bruises it and supplies a replacement.
- 3
Pack the fruit
Lift, carry to the marked tray, and press Space to release. The fruit must land inside the tray to count. Pack all three fruits.
Ana Özellikler
Food handling · compliant robotics
Soft grippers conform around delicate objects. This mission illustrates the tradeoff between enough grip to hold an object and excessive pressure that damages it. Pressure values are illustrative.
Keyboard and touch controls
Use the on-screen controls or keyboard shortcuts. Restart begins a fresh mission.
Sıkça Sorulan Sorular
Is this a real robot controller?
No. This is a simplified educational simulation. It does not connect to physical robots or reproduce real operating procedures.